Our research focusses on developing safe and robust algorithms for perception, decision-making, and control of autonomous mobile machinery used in outdoor work environments. From task automation for operator assistance and teleoperations, to machine autonomy for autonomous operations.

In the following video below, Professor Reza briefly introduces the research. Curious about the details? You can read more here: AMM Research Focus

Research Focus


YouTube video thumbnailPlay video on YouTube (opens in new tab)

Roadmap 2025 to 2030

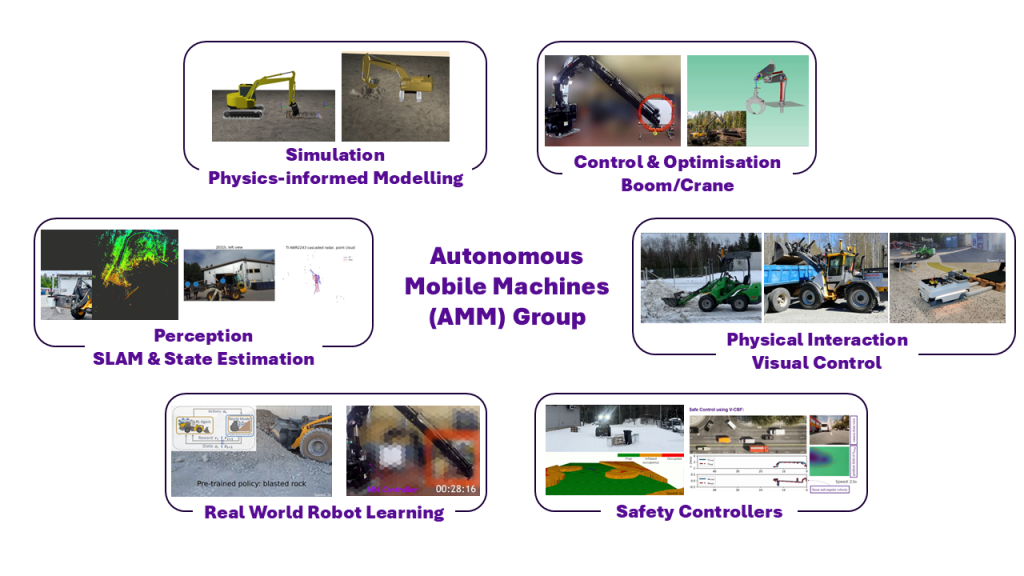
Research summary of AMM group with pictures. Simulation with Physics-informed Modelling, Control & Optimisation of Boom/Crane, Perception with SLAM & State Estimation, Physical Interaction through Visual Control, Real World Robot Learning, and Safety Controllers.

Research Infrastructure

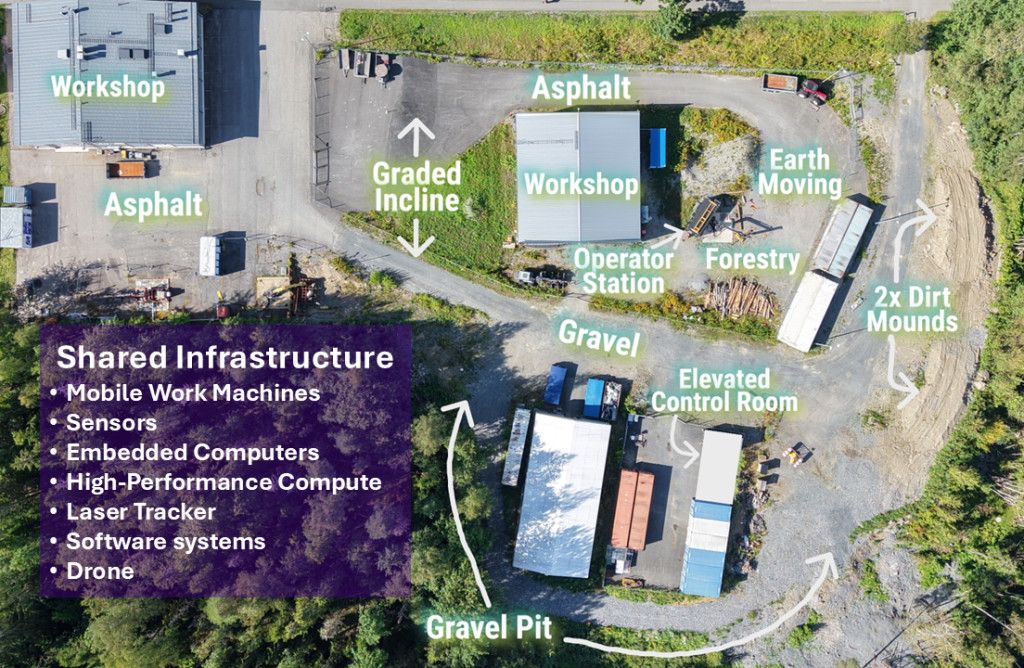
A drone view image of proving grounds with different features labelled with names.

Practical Applications

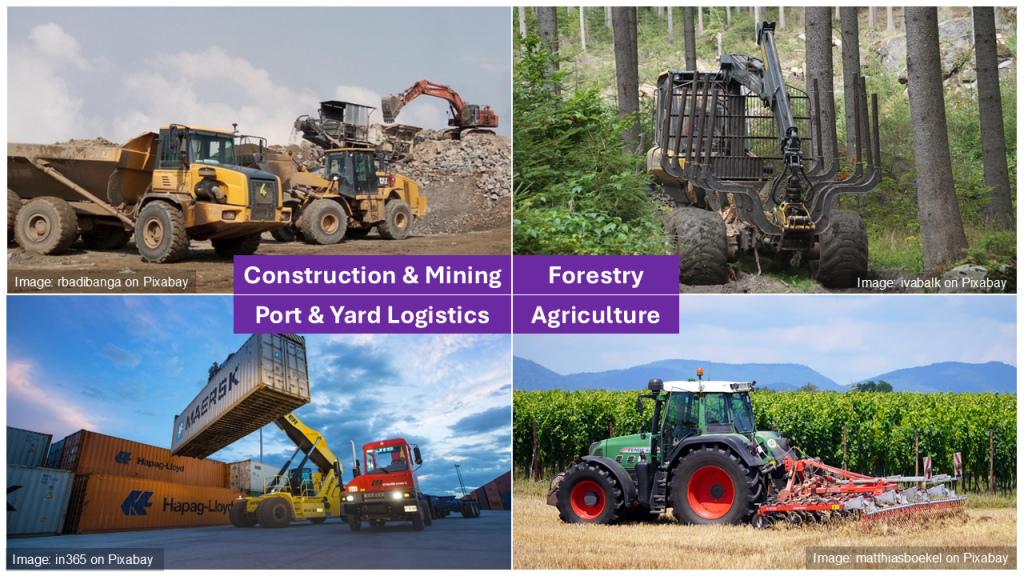
Representative images of mobile machines in mining, forestry, agriculture, and yard/port logistics applications.